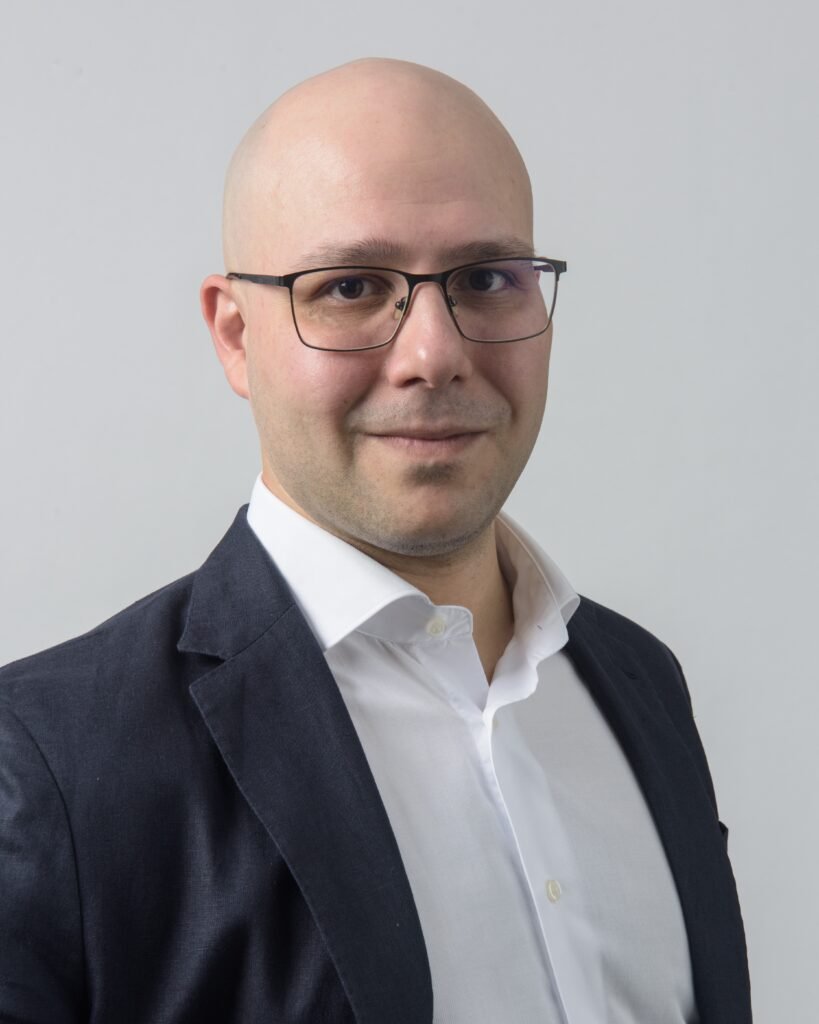
Researcher and Engineer in Optimization, Reinforcement Learning and Stochastic Control
I am a researcher and engineer working on sequential decision-making under uncertainty and on the control of large-scale multi-agent systems. My work combines predictive control methods, optimization, reinforcement learning and deep learning, and I have experience in several application domains such as power systems, robotic systems, UAVs and transportation networks.
I completed my PhD in 2026 at the Delft Center for Systems and Control (DCSC) of Delft University of Technology (TU Delft). In 2025 I was a visiting researcher in the Oxford Control and Verification (OXCAV) group at the University of Oxford, working on the integration of abstraction-based control and predictive optimization for safety-critical systems.
My PhD thesis addresses two problems in the control of large-scale networked systems:
1. Scalable control of large networks. How can a network be split into subsystems that are controlled with non-centralized predictive strategies, improving scalability and reliability while retaining adequate performance? I proposed a general partitioning strategy that selects the fundamental subsystems of a network and aggregates them to minimize a global performance metric, and I wrote a systematic review of partitioning approaches in the literature. To test these methods, I built EEA-ENB, an open-source benchmark of the European electricity network with 27 control areas for distributed predictive control and multi-agent reinforcement learning.
2. Safe control of nonlinear stochastic systems. How can such systems satisfy safety requirements while still performing well? I developed Abstraction-MPC, a multi-level framework that computes a safe policy on an interval Markov decision process (IMDP) abstraction of the system and then refines it with an online model predictive controller. In simulations it improves performance relative to the abstraction-based robust policy by up to 52% while keeping formal probabilistic safety guarantees.
The results of my research work can be accessed in the Publications section.
Current Work
I am developing distributed distributed deep reinforcement learning for load frequency control, physics-informed neural networks for satellite-based photovoltaic forecasting in real-time power system control, and ConsensusLLM, which extends consensus algorithms from distributed control to the coordination of LLM-based multi-agent systems.
An updated list of my current (publicly available) projects is available in the Projects section.
My Background
My education is in control engineering and robotics. I hold a BSc in Computer and Automation Engineering (2015) and an MSc in Control Engineering (2021) from Sapienza University of Rome, both with the top grade of 110/110, and cum laude for the MSc. During those years, I worked on projects in control, robotics and embedded systems, including the Kinesiometer, a medical device prototype (hardware and software) that I designed and built on commission. During a research visit at the Surgical Robotics Laboratory at the University of Twente for my Master’s thesis, I worked on modeling and control of soft robots under magnetic actuation. The thesis demonstrated wireless actuation of a soft micro-robot using a single mobile electromagnet mounted on a robotic arm, including field model identification, feedback control design and experiments on a physical platform.
Contact Information
If you’d like to get in touch for any inquiry about my present or past work, or for any collaboration proposal, you can write to me at contact@ariccardi.com.